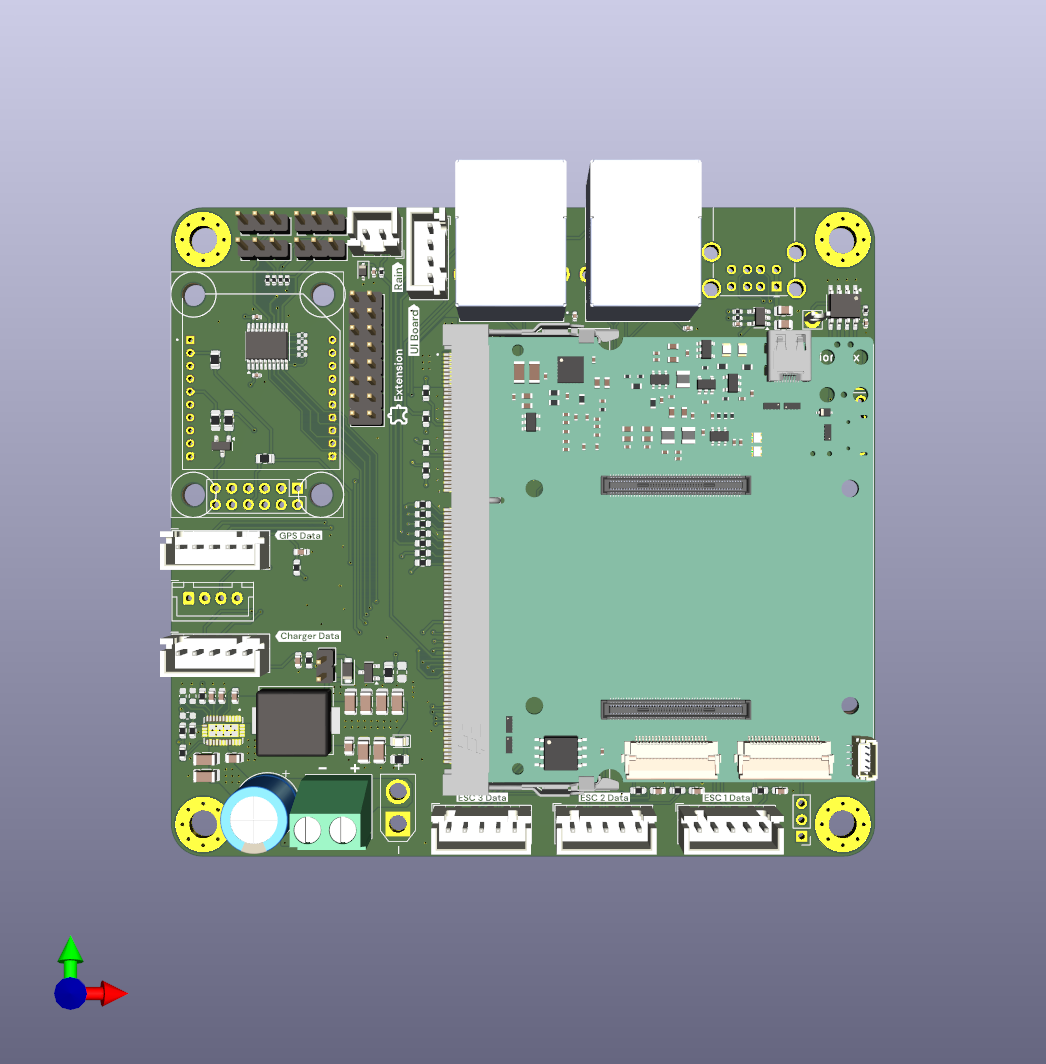
The Universal Logic Board is a mainboard for building robots. It’s designed around the xCore compute module and packs everything needed to power, connect, and control a robot into a single PCB — so you can go from module to working robot without designing your own carrier.
What it does
The xCore does the heavy lifting — real-time control on the STM32H723, Linux on the CM4, Ethernet, and an IMU. This board gives it wide-range power, plenty of connectivity, and the real-world I/O a robot actually needs.
Features
| Feature | Details |
|---|---|
| xCore slot | SODIMM connector for the xCore (STM32H723 + CM4 + IMU + Gigabit switch) |
| Input voltage | 7 V – 32 V wide range |
| Power | Onboard switching DC/DC regulator for the board and peripherals |
| GPS header | Dedicated connector for a GPS / RTK-GPS module |
| Networking | 2× Gigabit Ethernet (RJ45) |
| USB | 2× USB 2.0 |
| UART | 5× UART (XH), four with an extra analog GPIO each — for xESC, external GPS, and more |
| I²C | 1× XH with I²C + analog GPIO — e.g. for the Charger Module |
| Safety | 4× Hall-sensor inputs for emergency switches / 5 V switch inputs |
| Sensors | Rain-sensor input, plus general-purpose GPIO headers |
Design files
KiCad schematics and PCB layout are on GitHub, licensed CC BY 4.0.