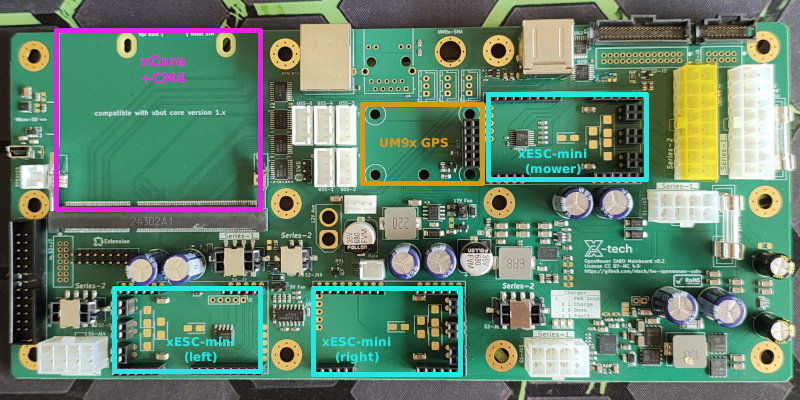
This carrierboard converts SABO (and rebadged John Deere) robotic mowers into OpenMower V2 robots. It’s the base board that ties the whole OpenMower V2 stack together for these models.
Compatible mowers
- SABO MOWiT 500F (Series I & II)
- John Deere Tango E5 (Series I & II)
What’s on the board
The carrierboard hosts the xCore and integrates everything needed for a running robot:
- Power & dock interface and onboard charger
- Networking for the compute stack
- ESC connections for the BLDC drive and cutter motors
- Emergency sensors — front wheel lifts, top-stop, handle-stop
- Battery interface over I²C
- CoverUI — buttons, LEDs, LCD backlight, and LC-display, with a context-driven button layout for both Series-I and Series-II hardware
Both hardware and firmware are marked complete on the project roadmap; firmware lives in fw-openmower-v2.
To build one
You’ll also need an xCore, a Raspberry Pi CM4/CM5, three xESC Mini controllers, and an RTK-GPS module with antenna. The step-by-step SABO guide is in the official OpenMower docs.
Design files on GitHub.